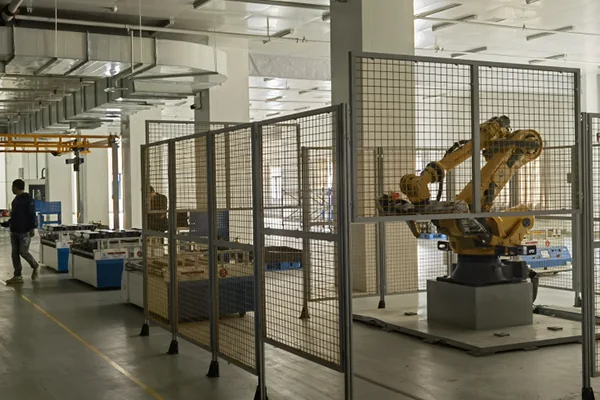
Robotic cover removal, AGV and suspended disassembly line
Combine robotic cover removal, AGV transport and suspended disassembly in one line. Robots handle the selected fasteners; downstream stations remove, test and collect modules or cells according to the feedstock.
Process flow
- Robotic cover removal
- AGV fixture transfer
- Suspended disassembly
- Testing & collection
Transport, fixtures and suspended support
AGVs transfer workpieces between stations along defined routes and target positions; tooling trolleys carry and locate the packs. Suspended support assists part support and transfer and connects with the selected disassembly tools and fixtures.
Fixture, lifting-device and trolley capacities depend on pack weight, dimensions and lifting points. AGV navigation, positioning and docking are planned together with aisles and station layouts.
Disassembly, testing and collection
A robotic top-cover fastener station is added at the front; after cover separation, AGVs transfer the pack onward. Operators remove and process modules or cells at the assigned stations, followed by testing, sorting and collection.
Conveyors can route sorted material to collection areas, with transport speeds and routing selected for the process. Stations can be networked for status monitoring, data recording and production management; automation scope is project-specific.
Equipment selection and line enquiries
Share your battery type, processing goals and site conditions so we can assess the process.